Every frame is a deadline. The system must extract useful visual information, reject noise, calculate a stable path, and command the vehicle quickly enough to stay precise through every curve.
International arenas
NXP Cup · Autonomous mobility
See the line. Own the curve.
An autonomous racing robot that transforms camera frames into steering decisions—combining computer vision, embedded processing, and control in a real-time pursuit of speed and precision.
1st placeNational qualifications · 2025
1st placeNational qualifications · 2026
2nd placeNational qualifications · 2026
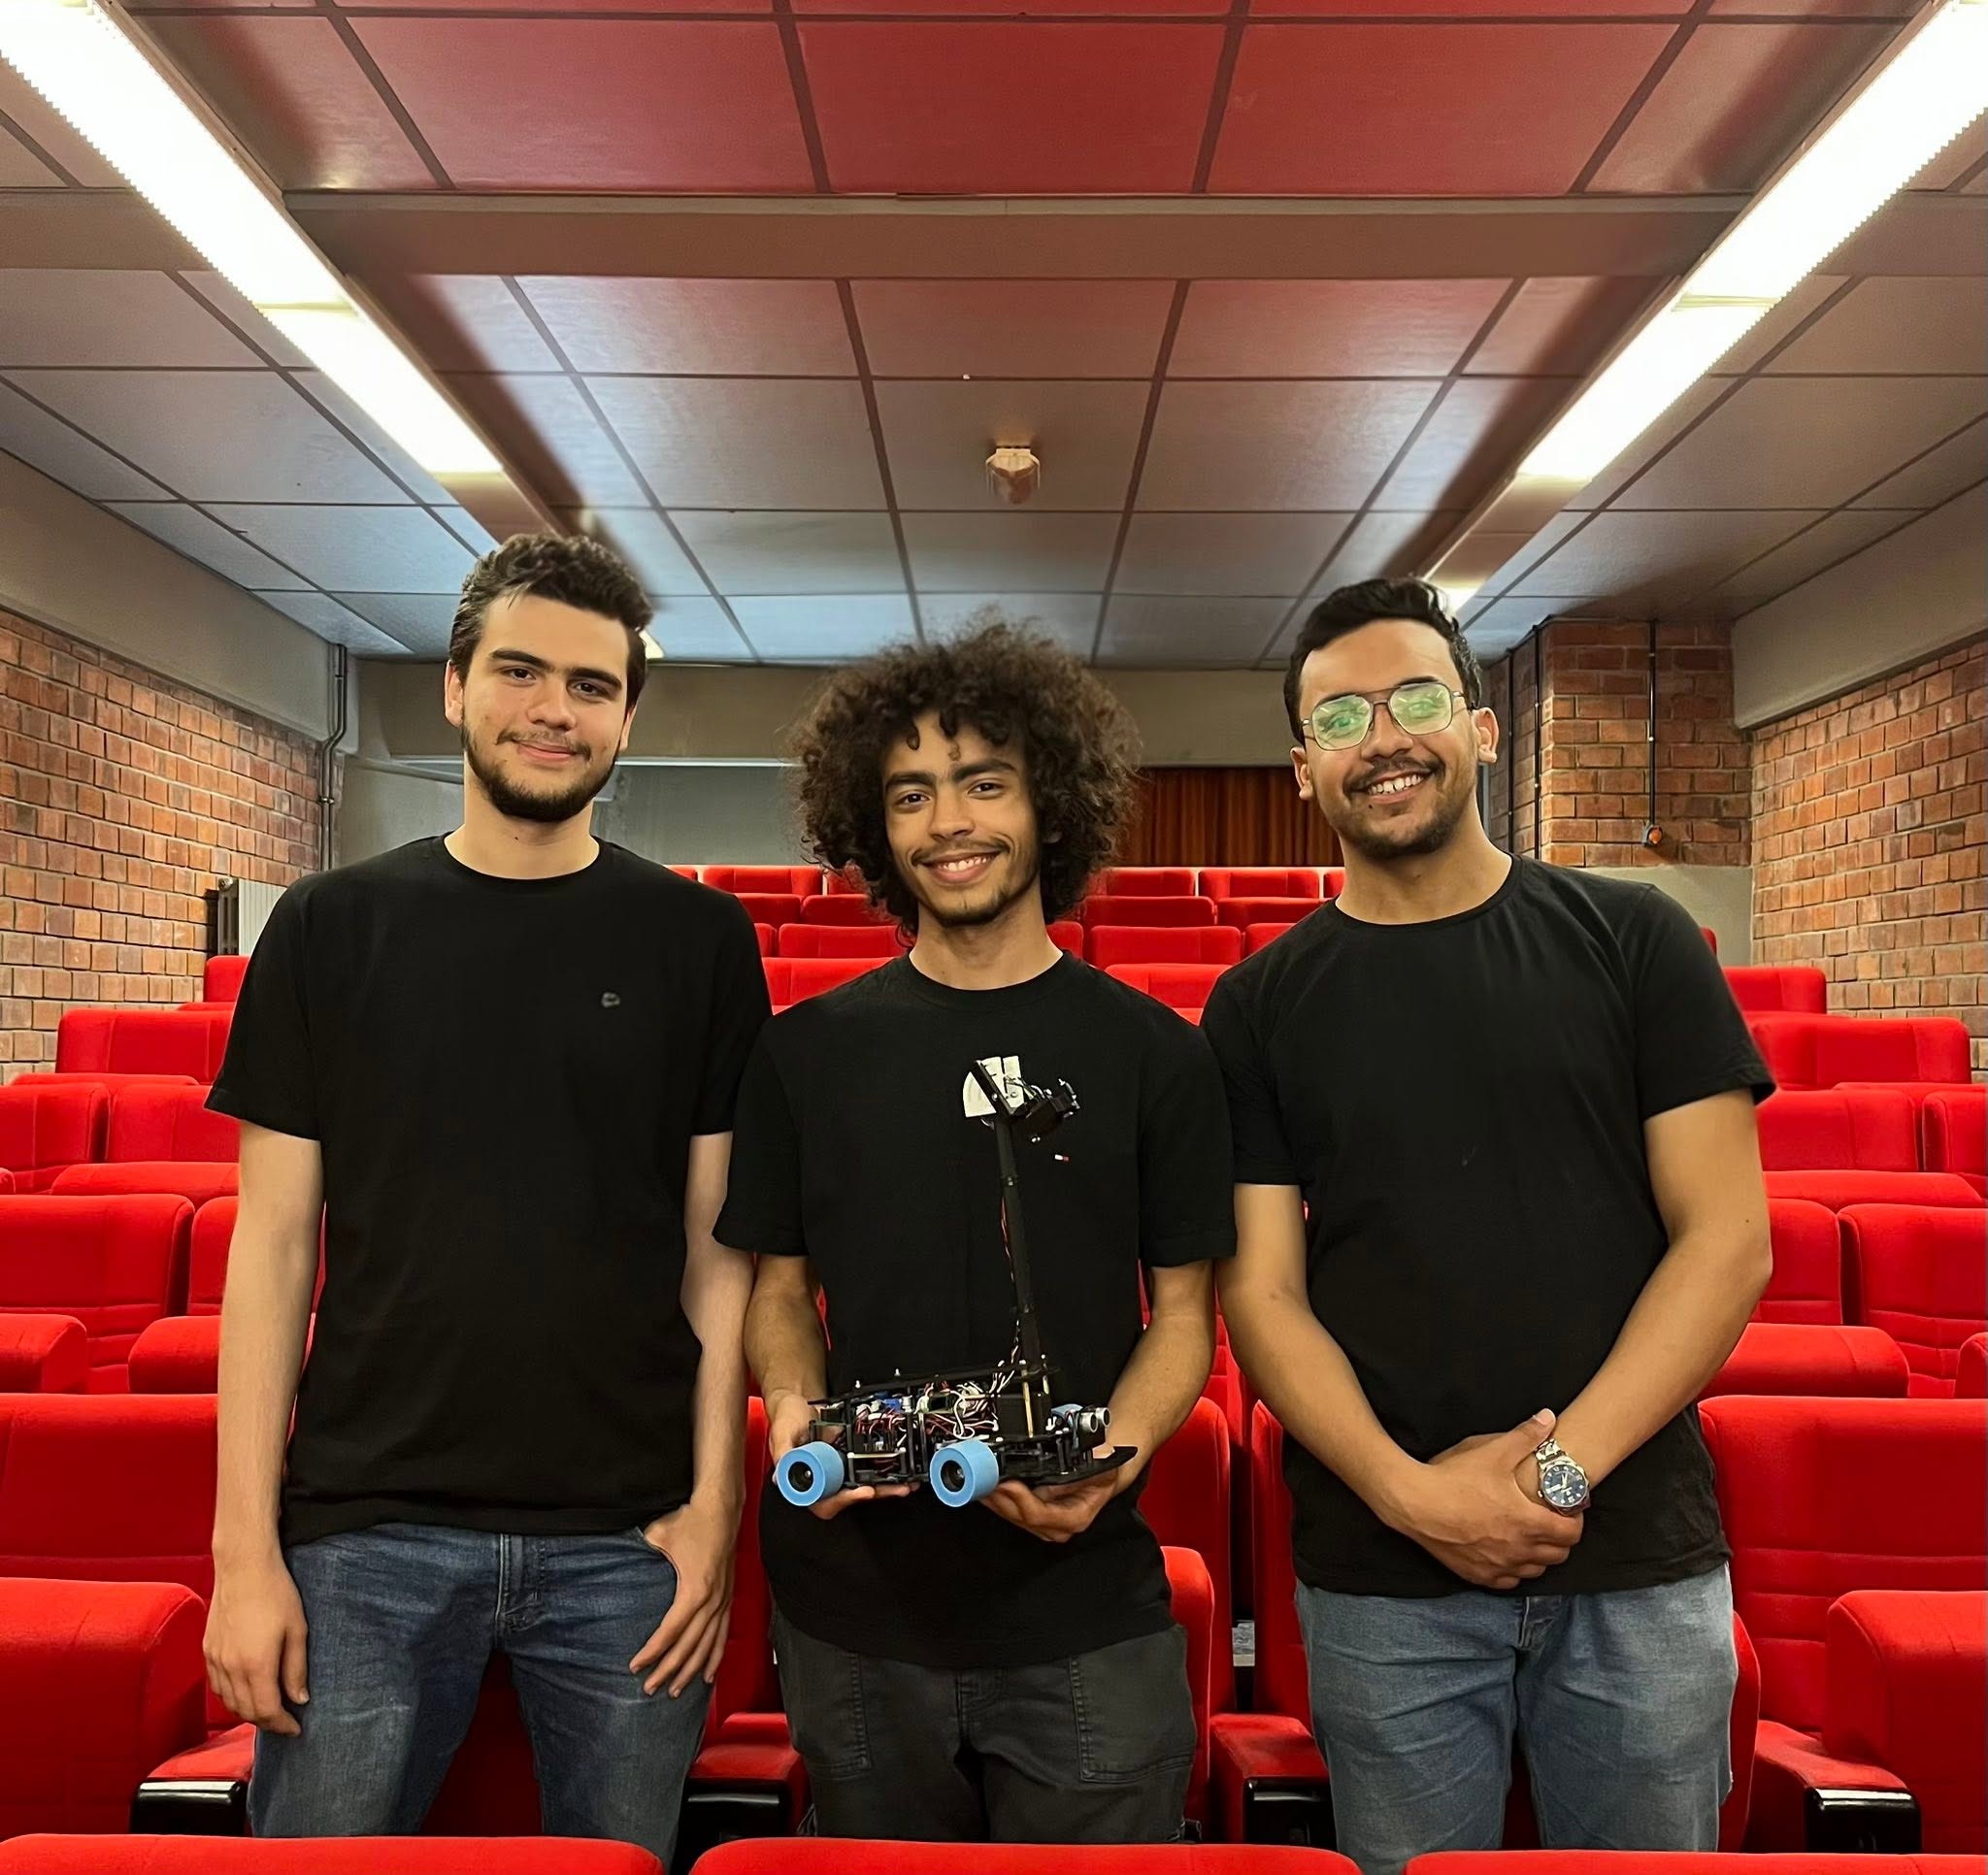
NXP CupPerception · Control · Speed
Computer visionLane detectionEmbedded AIControlSpeedPrecision
01
The challenge
Autonomy at racing speed
Perceive. Decide. Move.
The NXP Cup asks students to build and race intelligent mobile systems. On the track, the vehicle has to interpret the lane, estimate the right steering response, and adapt its speed without human input.
Live racing-line simulation
02
The system
From photons to motion
A full pipeline. In real time.
Speed is only useful when the full perception-and-control loop remains stable. Each layer has to be efficient, measurable, and tuned with the others.
PIPELINE / 01
Capture
Acquire consistent frames from the camera while the vehicle moves through changing track conditions.
PIPELINE / 02
Perception
Extract lane information with a computer-vision pipeline designed for accuracy and low latency.
PIPELINE / 03
Control
Convert the estimated path into smooth steering and speed commands that remain stable through curves.
PIPELINE / 04
Optimization
Measure the entire loop, remove bottlenecks, and tune for the fastest reliable lap—not a single lucky run.
Engineering the racing line
Measure. Tune. Repeat.
Understand the track
Define what the camera should detect and how uncertainty enters the image.
Connect the loop
Integrate vision, processing, steering, propulsion, and system diagnostics.
Balance the car
Adjust perception and control together for stability before chasing speed.
Trust the system
Validate repeatedly until fast autonomous behavior holds under pressure.
03
Competition archive
From track to podium
Precision shared. Progress remembered.
The vehicle is the visible result. Behind it are the test laps, code reviews, late adjustments, and the team learning to make every millisecond count.